AI
VLASH: asynchronous robot control
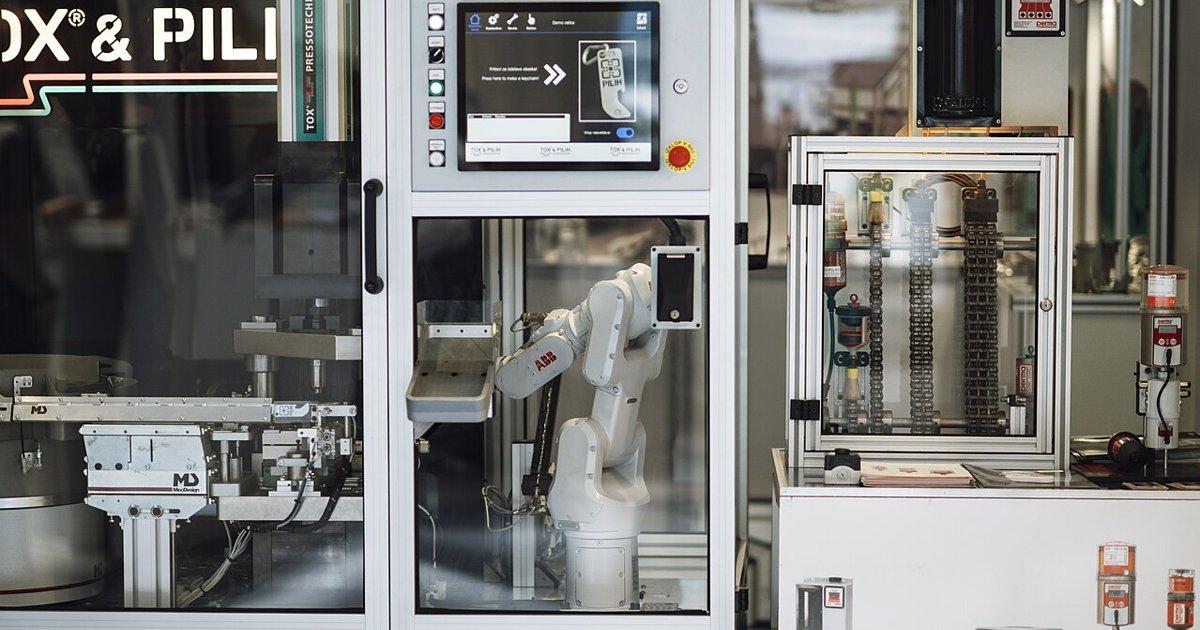
The MIT research prototype uses future-state-aware asynchronous inference for vision-language-action models, preparing the next action while the current one runs to cut latency. Autonomy is learned policy control within a human-designed task setup, not a fully autonomous general-purpose robot.
It decouples heavy VLA inference from motion. Concerns: author-reported metrics, hardware sensitivity and no independent safety validation.